Yahboom Raspbot v2 (Boomy) — MCP Server, Webapp & Documentation
📖 Installation Guide — quick start, manual setup, and troubleshooting
接入你的智能体
發布者自己的指令。不是 PlugMCP 端點。
用我們的金鑰與日誌託管一份副本。
mcpb https://github.com/sandraschi/yahboom-mcp/releases/download/v2.5.0b1/yahboom-mcp-v2.5.0b1.mcpbClaude Code 沒有本機指令的安裝連結。複製下方指令並在終端機中執行。
claude mcp add sandraschi-yahboom-mcp -- mcpb https://github.com/sandraschi/yahboom-mcp/releases/download/v2.5.0b1/yahboom-mcp-v2.5.0b1.mcpb在終端機中執行。
{ "mcpServers": { "sandraschi-yahboom-mcp": { "command": "mcpb", "args": [ "https://github.com/sandraschi/yahboom-mcp/releases/download/v2.5.0b1/yahboom-mcp-v2.5.0b1.mcpb" ] } }}claude_desktop_config.json
遠端 URL 還是本機指令? 兩種安裝方式的差異
來自發布者
📖 Installation Guide — quick start, manual setup, and troubleshooting
FastMCP 3.2 server plus Webapp for Yahboom Raspbot v2 robot car, ros2, raspberry pi
Download for Windows:
yahboom-mcp-2.5.0-setup.exe— installer with webapp + embedded backend, one shortcut. The installer is unsigned: SmartScreen will warn — click More info > Run anyway. Claude Desktop users can instead install the MCP bundle (one-liner below).
Claude Desktop only (MCPB bundle):
irm https://github.com/sandraschi/yahboom-mcp/releases/latest/download/install.ps1 | iex
Every other client (Cursor, Windsurf, OpenCode, Claude Code) — stdio via uvx:
{
  "mcpServers": {
    "yahboom-mcp": {
      "command": "uvx",
      "args": ["--from", "git+https://github.com/sandraschi/yahboom-mcp", "yahboom-mcp", "--mode", "stdio"],
      "env": { "YAHBOOM_IP": "192.168.1.11" }
    }
  }
}
Developers from source:
git clone https://github.com/sandraschi/yahboom-mcp
cd yahboom-mcp
just
This opens an interactive dashboard showing all available commands. Run just bootstrap to install dependencies, then just serve or just dev to start.
If you don't have just installed:
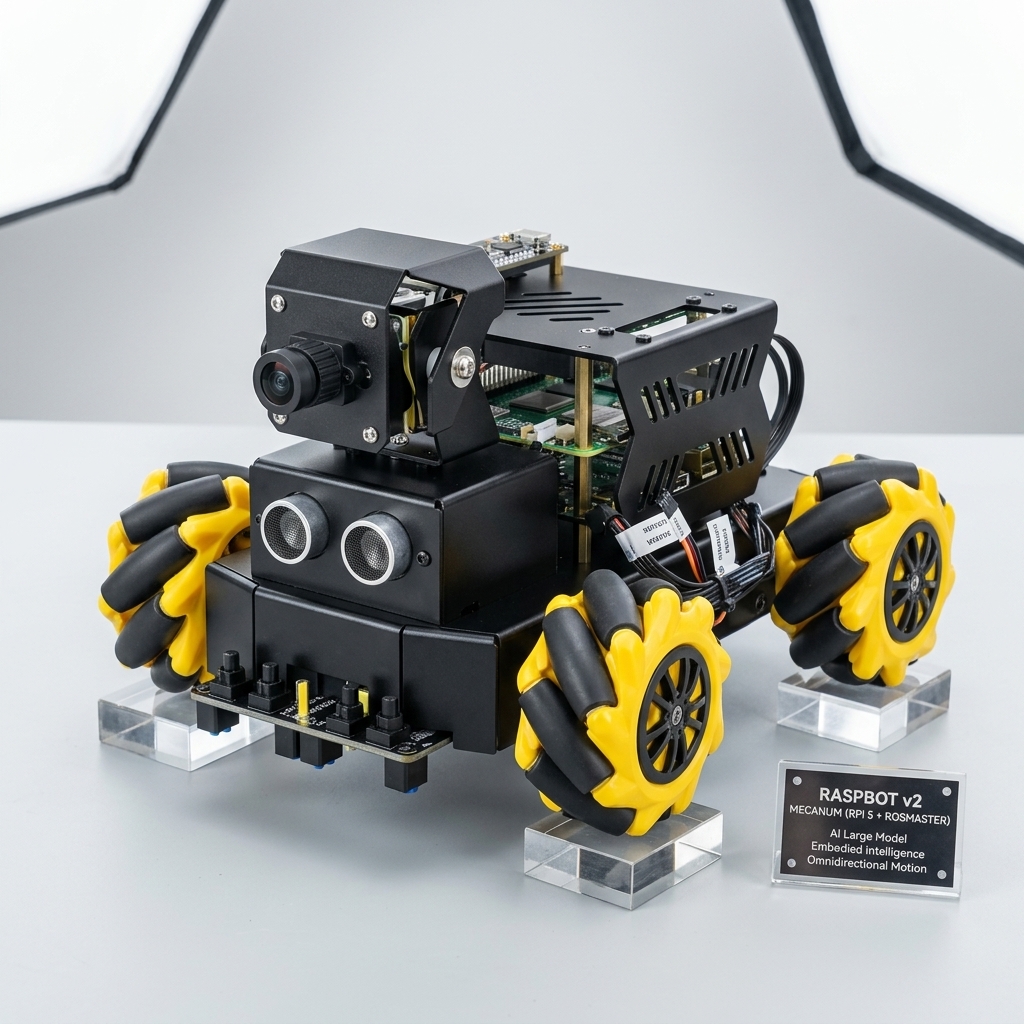
Boomy is a Yahboom Raspbot v2 (Mecanum Version) robot car. Weighing in at approximately 1.0 kg and costing roughly $300 (fully loaded with a Raspberry Pi 5 16GB), it provides a unified platform for testing sensor integration, ROS 2 orchestration, and agentic (AI-driven) robotics. It's also great fun for kids of all ages.
Yahboom is a prominent player in the Chinese robotics and STEM education industry. They offer a diverse range of hardware platforms:
Boomy utilizes a "Double-Stack" controller model to bridge real-time physical reliability with high-level cognitive tasks:
For scaled deployments, Boomy can operate in a Pi-less Swarm mode:
This project clearly distinguishes between human-operable controls and machine-optimized interfaces:
yahboom-mcp works completely standalone. You can optionally connect it with companion servers in the sandraschi fleet to unlock extended features:
Self-Contained Companions: Fleet companions operate independently. Installing companions does not trigger transitive dependency chains.
/dashboard) — First page: basic robot link (gateway, target IP, ROS · SSH · video) and operator hints when the Raspbot is off or Goliath has no AP/Ethernet path./diagnostics) — Detail: ROS topic explorer, node list, resync / hard reset, SSH shell, stack health table (same stack payload as the dashboard when available)./logs) — Live yahboom-mcp log stream (SSE) on Goliath.Historical status logs and legacy research are preserved in the docs/archive/ directory.
This project adheres to SOTA 2026 industrial standards for high-fidelity agentic orchestration:
print statements in core handlers (T201).:11434) and LM Studio (:1234). GPU metrics via nvidia-smi.just lint, just fix, just dev).FastMCP 3.2 server plus Webapp for Yahboom Raspbot v2 robot car, ros2, raspberry pi
{ "mcpServers": { "sandraschi-yahboom-mcp": { "command": "mcpb", "args": [ "https://github.com/sandraschi/yahboom-mcp/releases/download/v2.5.0b1/yahboom-mcp-v2.5.0b1.mcpb" ] } }}工具
尚無工具清單。遠端伺服器會在首次健康檢查後取得工具清單。
常見問題
在本頁複製適用於 Cursor、Claude Desktop、Claude Code 或 VS Code 的 stdio 設定。它使用發布者的安裝方式,而不是 PlugMCP 代理伺服器。
這筆記錄未列出必要的環境變數。
Yahboom 透過 stdio 在本機執行。
上次檢查時間:2026-10-28。 FastMCP 3.2 server plus Webapp for Yahboom Raspbot v2 robot car, ros2, raspberry pi
