ROS2 Rosout Rosbag MCP Server
A Model Context Protocol (MCP) server that loads ROS2 rosbag files containing log information (/rosout), builds an in-memory database, and provides SQL-like querying capabilities.
Agenten stärken
Installation vom Herausgeber. Kein PlugMCP-Endpunkt.
Host a copy with our keys and logs.
Noch kein paketiertes Release in der Registry. Folgen Sie der README des Repositorys.
Remote-URL oder ein Befehl auf Ihrem Rechner? Worin sich die beiden Installationen unterscheiden
Auf PlugMCP ausführen
A new server you create. It is not this listing's official endpoint. Use the publisher install when you want their URL and their credentials.
StartenVom Herausgeber
A Model Context Protocol (MCP) server that loads ROS2 rosbag files containing log information (/rosout), builds an in-memory database, and provides SQL-like querying capabilities.
A Model Context Protocol (MCP) server that loads ROS2 rosbag files containing log information (/rosout), builds an in-memory database, and provides SQL-like querying capabilities.
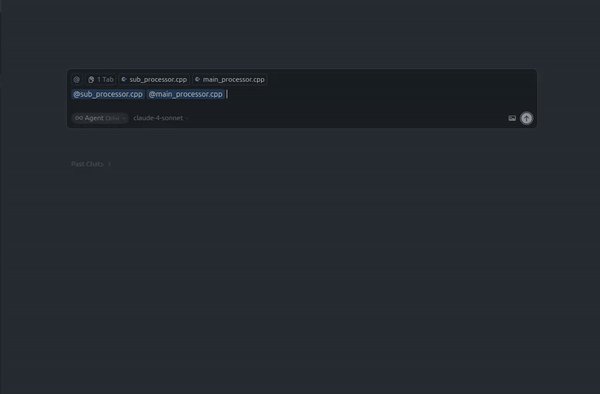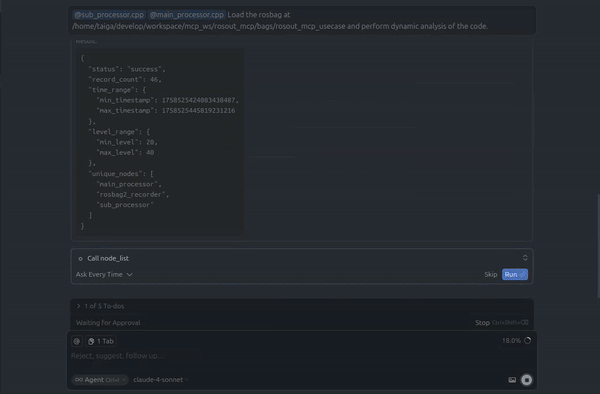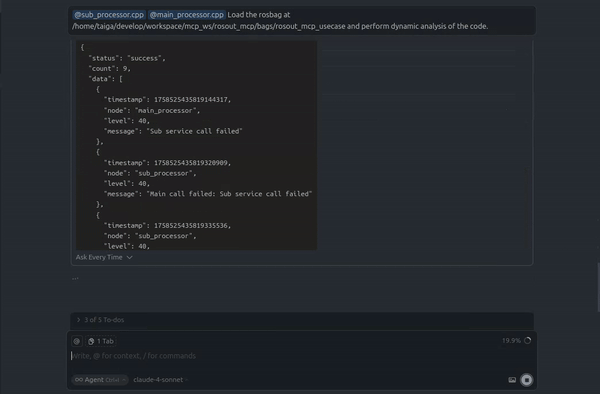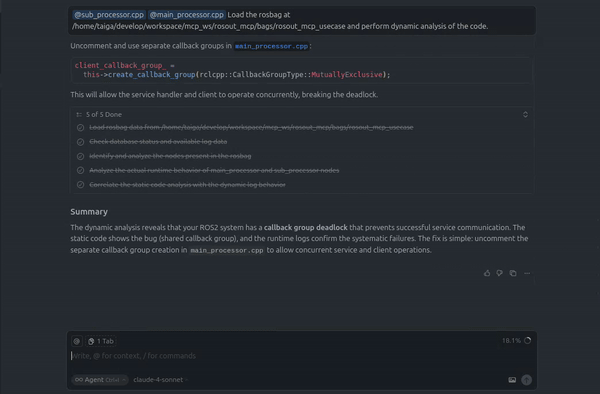
This package provides:
/rosout topic dataTo run the MCP server using the Docker Hub image, add the following to your mcp.json configuration:
{
  "mcpServers": {
    "rosout_db_server": {
      "command": "docker",
      "args": [
        "run",
        "-i",
        "--rm",
        "--net=host",
        "--mount",
        "type=bind,src=<LOCAL_BAG_DIR>,dst=<LOCAL_BAG_DIR>,readonly",
        "araitaiga/rosout-mcp:latest"
      ]
    }
  }
}
Note: Replace <LOCAL_BAG_DIR> with the actual path to the directory containing your rosbag files.
curl -LsSf https://astral.sh/uv/install.sh | sh
Add this MCP server to your mcp.json configuration:
{
  "mcpServers": {
    "rosout_db_server": {
      "command": "uvx",
      "args": [
        "--python 3.12",
        "--from",
        "git+https://github.com/araitaiga/rosout_mcp",
        "rosout-mcp"
      ]
    }
  }
}
{
  "mcpServers": {
    "rosout_db_server": {
      "command": "uvx",
      "args": [
        "--python 3.10",
        "--from",
        "git+https://github.com/araitaiga/rosout_mcp",
        "rosout-mcp"
      ]
    }
  }
}
Prepare your ROS2 application with sufficient logging for runtime analysis
Build and run your ROS2 application
Record rosout data:
ros2 bag record /rosout
Use MCP client to analyze the recorded data:
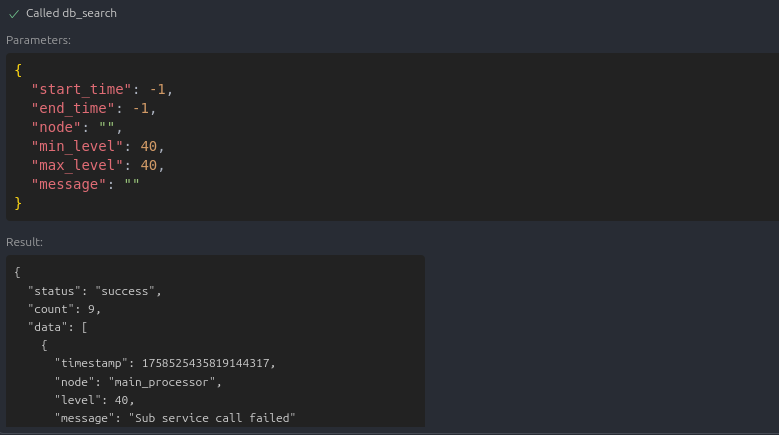
sample user code repository
https://github.com/araitaiga/rosout_mcp_usecase
rosbag_load: Load ROS2 rosbag files into in-memory databasedb_search: Search logs with filters (time range, node, log level, message content)db_status: Get database statistics and informationnode_list: List all unique node names in the databasedb_init: Initialize/clear the in-memory databaseFor local development and debugging:
# clone rosout_mcp
cd /path/to/rosout_mcp
uv pip install -e .
npx @modelcontextprotocol/inspector uv run rosout-mcp
(jazzy)
npx @modelcontextprotocol/inspector uvx --python 3.12 --from git+https://github.com/araitaiga/rosout_mcp rosout-mcp
Note: You need to have ROS2 installed in your environment, and the --python version should match the ROS2 requirements.
cd /path/to/rosout_mcp/docker

# Build and run the MCP server
./build_run.sh

# Or run with specific options:
./build_run.sh inspector   # Start MCP inspector
./build_run.sh bash        # Start bash shell
# Pull the image from Docker Hub
# Start MCP inspector
LOCAL_BAG_DIR=/path/to/your/bag
docker run -it --net host --rm --name rosout-mcp-container \
  --mount type=bind,src=${LOCAL_BAG_DIR},dst=${LOCAL_BAG_DIR},readonly \
  araitaiga/rosout-mcp:latest \
  npx @modelcontextprotocol/inspector uvx --from git+https://github.com/araitaiga/rosout_mcp rosout-mcp
This will start the MCP inspector at http://localhost:6274 where you can:
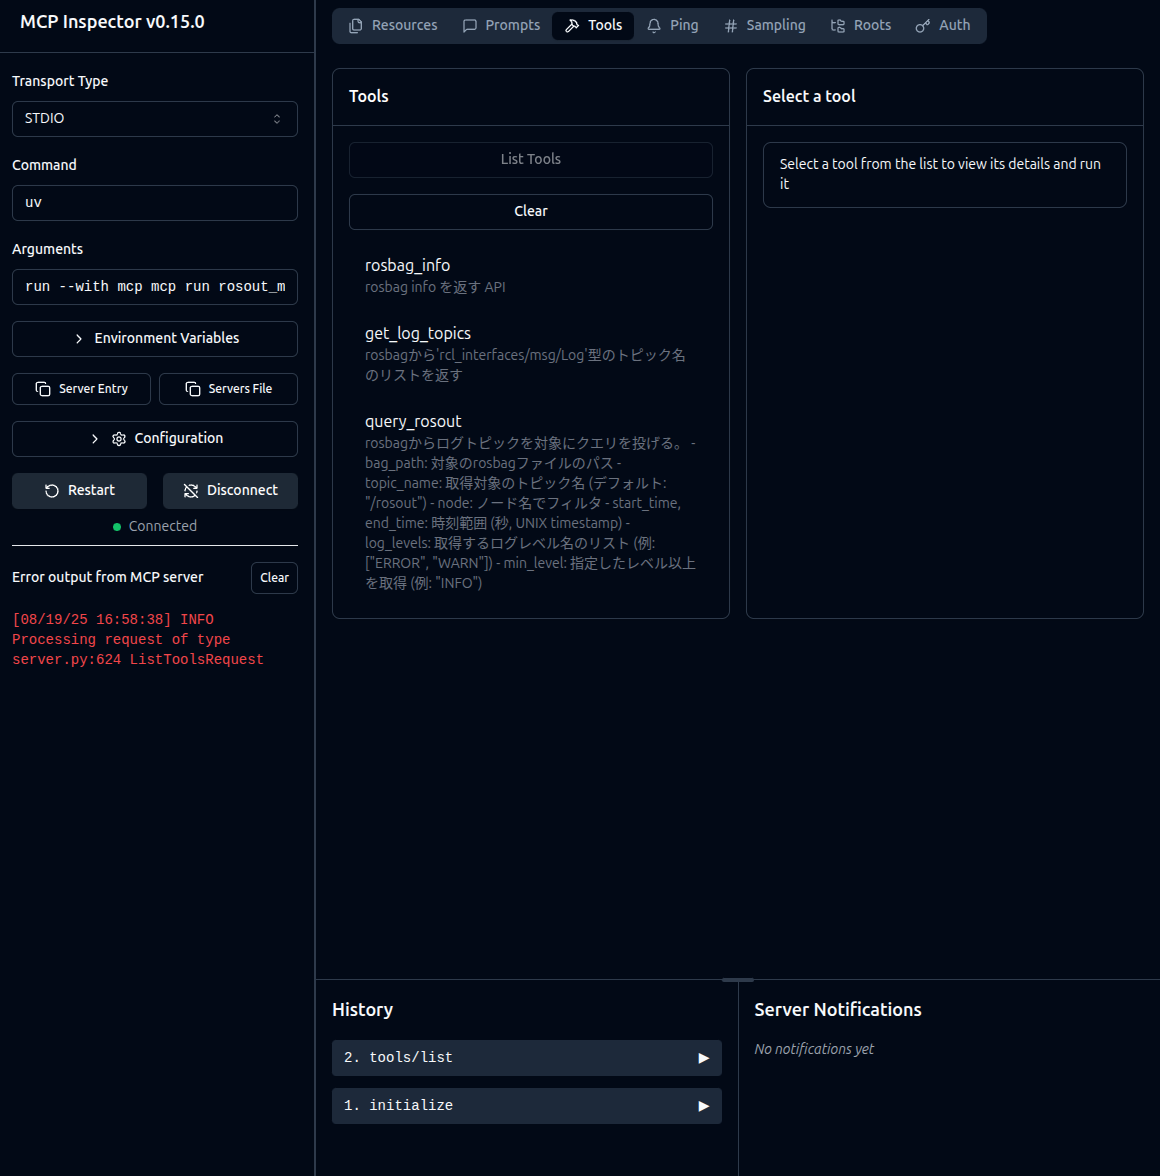
Run the test suite:
uv run pytest
A Model Context Protocol (MCP) server that loads ROS2 rosbag files containing log information (/rosout), builds an in-memory database, and provides SQL-like querying capabilities.
Tools
Noch keine Tool-Liste. Remote-Server erhalten eine nach dem ersten Health-Check.
FAQ
Kopieren Sie auf dieser Seite die stdio-Konfiguration für Cursor, Claude Desktop, Claude Code oder VS Code. Sie nutzt die Installation des Herausgebers, keinen PlugMCP-Proxy.
In diesem Eintrag ist keine erforderliche Umgebungsvariable aufgeführt.
Rosout läuft lokal über stdio.
Zuletzt geprüft: 2026-10-28. A Model Context Protocol (MCP) server that loads ROS2 rosbag files containing log information (/rosout), builds an in-memory database, and provides SQL-like querying capabilities.
