openmcpgdb
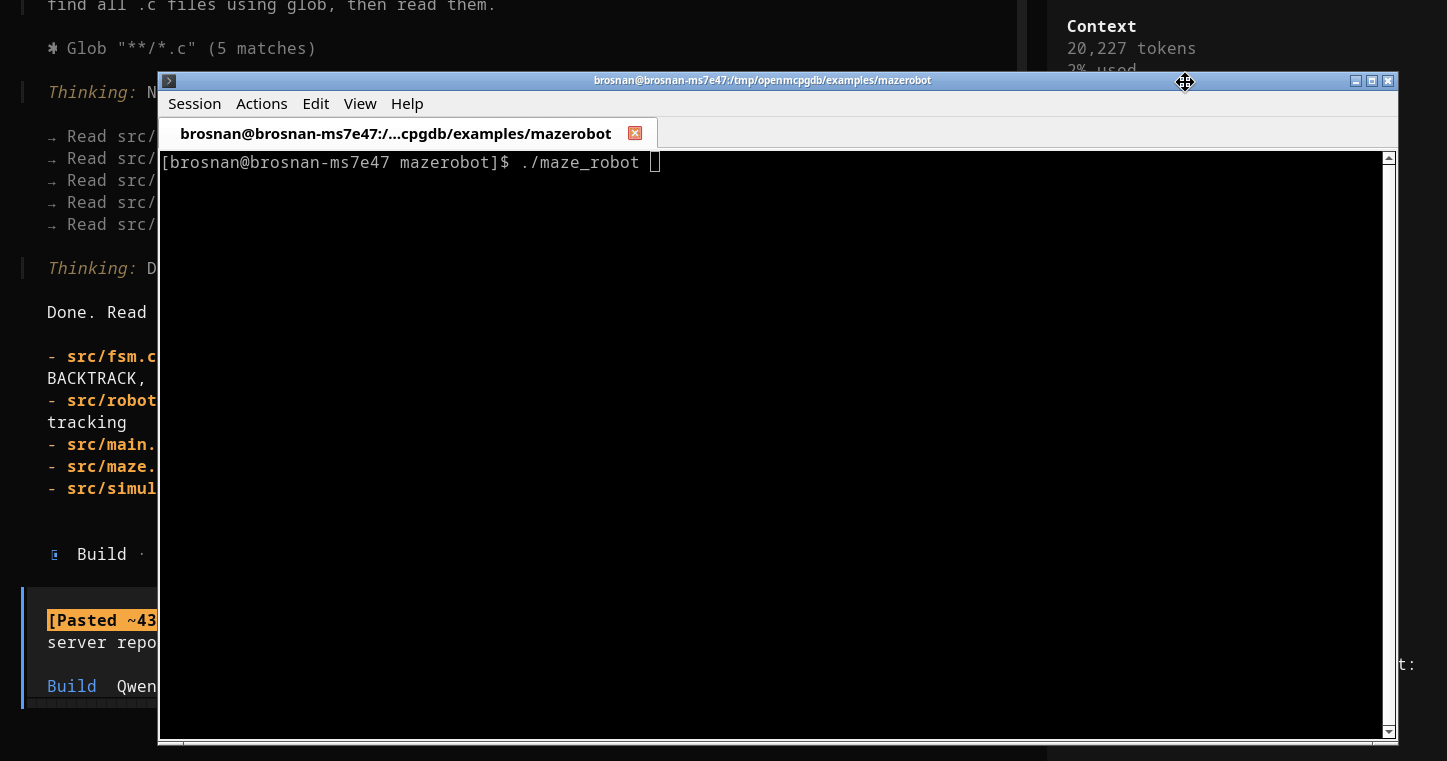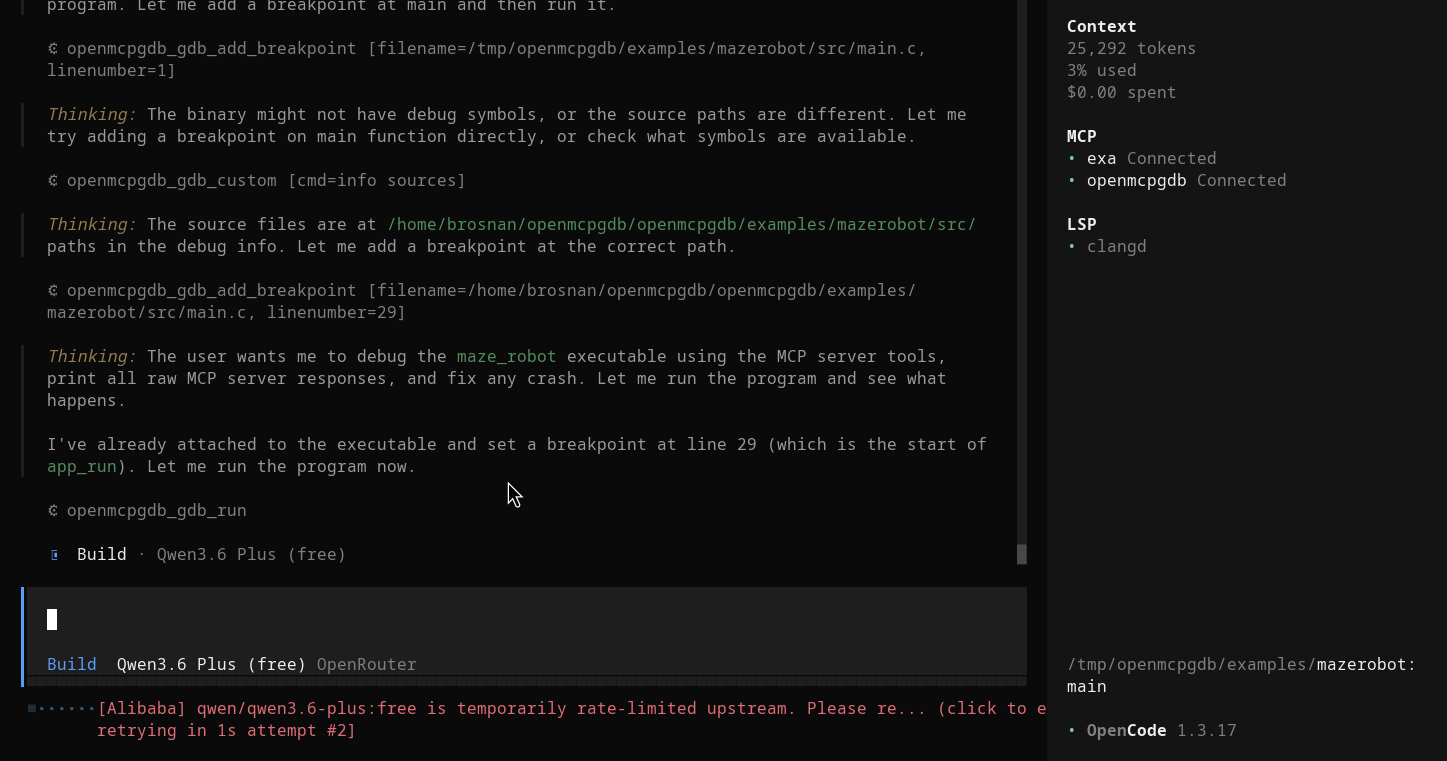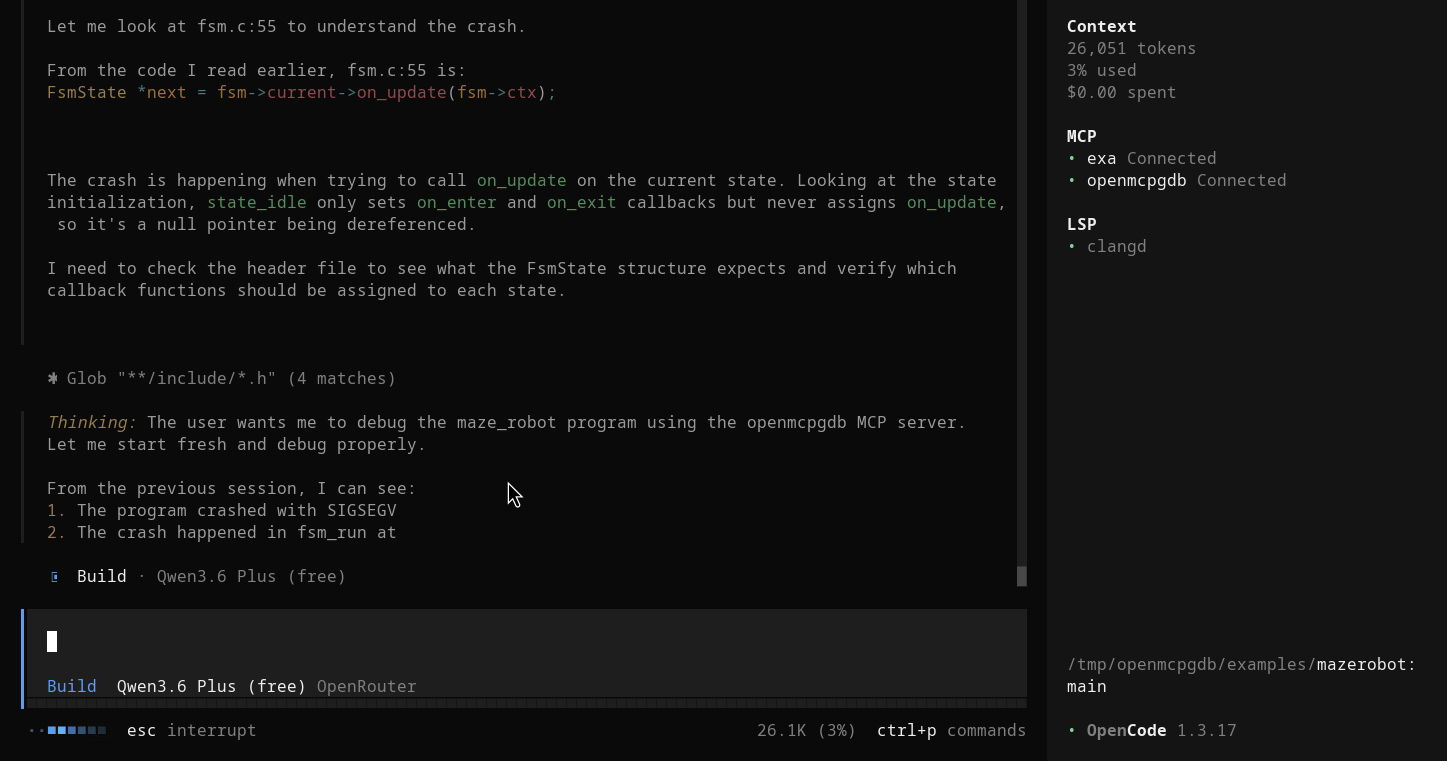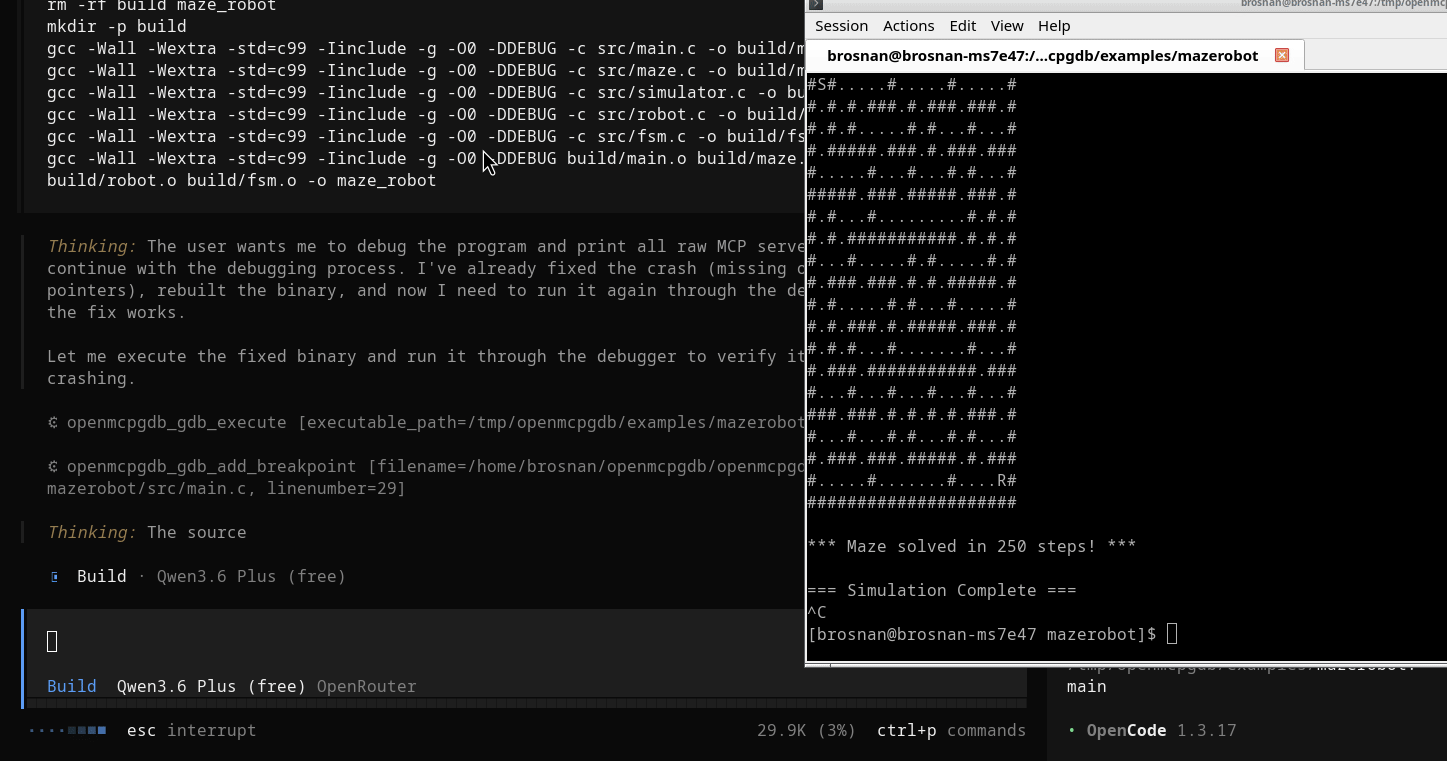
openmcpgdb is an asynchronous Rust MCP server for debugging native programs through GDB.
It is implemented with the rmcp crate and exposes a full gdb_* tool API for MCP clients (Codex, Claude Code, opencode-compatible clients).
Power your agent
Install from the publisher. Not a PlugMCP endpoint.
Host a copy with our keys and logs.
No packaged release in the registry yet. Follow the repository README.
Remote URL or a command on your machine? How the two installs differ
Run on PlugMCP
A new server you create. It is not this listing's official endpoint. Use the publisher install when you want their URL and their credentials.
LaunchFrom the publisher
openmcpgdb is an asynchronous Rust MCP server for debugging native programs through GDB.
It is implemented with the rmcp crate and exposes a full gdb_* tool API for MCP clients (Codex, Claude Code, opencode-compatible clients).
Interactive MCP server to control gdb. Fully featured and written in rust
rmcp (tools/list, tools/call support).https://... and http://... streamable HTTP mode (default)stdio://... for stdio MCP wiring when neededexamples/mazerobot/maze_robotgit clone https://github.com/BrosnanYuen/openmcpgdb.git
cd openmcpgdb
# Change the settings to point to your codebase and executable
# Use HTTP for server compatibility
vim config.json
# Run MCP server
cargo run --bin openmcpgdb -- config.json
claude.json{
"mcpServers": {
"openmcpgdb": {
"type": "http",
"url": "http://localhost:9443"
}
}
}
config.toml config[mcp_servers.openmcpgdb]
url = "http://localhost:9443"
enabled = true
opencode.json config{
"$schema": "https://opencode.ai/config.json",
"mcp": {
"openmcpgdb": {
"type": "remote",
"url": "http://localhost:9443",
"enabled": true
}
}
}
/usr/bin/gdb)src/main.rs: server entrypointsrc/runtime.rs: transport/runtime bootstrappingsrc/server.rs: MCP tool routing and handlerssrc/session.rs: per-client worker thread and operation executionsrc/gdb.rs: real and mock GDB backendssrc/bin/interactive_client.rs: interactive MCP clienttests/mazerobot_mcp_client.rs: integration MCP client test against mazerobotconfig.json: default config templateThe server loads JSON config from the first CLI argument, defaulting to config.json in project root.
All filesystem paths must be absolute.
Example:
{
  "gdb_path": "/usr/bin/gdb",
  "gdb_options": "",
  "codebase_dir": "/home/brosnan/openmcpgdb/openmcpgdb/examples/mazerobot",
  "executable_path": "/home/brosnan/openmcpgdb/openmcpgdb/examples/mazerobot/maze_robot",
  "mcp_server_name": "MCP GDB Server",
  "mcp_server_url": "https://localhost:9443",
  "display_lines_before_current": 7,
  "display_lines_after_current": 8,
  "display_backtrace": 50,
  "display_variable_list": 20,
  "display_join_current_code": true
}
display_join_current_code controls how current_code is returned:
false: object map keyed by line numbertrue: single joined string in the format line | source with newline separatorsmcp_server_urlhttps://localhost:9443http://host:port/path or https://host:port/path: run streamable HTTP on that bind address/path.stdio://...: run MCP over stdio.Note: https:// is parsed and accepted, but this project currently binds plain TCP HTTP directly. For real TLS, run behind a TLS-terminating reverse proxy.
cargo build
Use default config:
cargo run --bin openmcpgdb -- config.json
Set config URL, for example:
"mcp_server_url": "https://localhost:9443"
Run:
cargo run --bin openmcpgdb -- config.json
Set:
"mcp_server_url": "stdio://local"
Run:
cargo run --bin openmcpgdb -- config.json
An interactive MCP client is included for manual testing against HTTP server mode.
Run:
cargo run --bin interactive_client -- config.json
Input format:
<tool_name> <json-args>
Examples of Debugging on local GDB:
gdb_execute {"executable_path":"/home/brosnan/openmcpgdb/openmcpgdb/examples/mazerobot/maze_robot"}
gdb_debugger_state {}
gdb_add_variable_list {"var":"robot->sim->robot_row"}
gdb_add_breakpoint {"filename":"/home/brosnan/openmcpgdb/openmcpgdb/examples/mazerobot/src/main.c","linenumber":20}
gdb_run {}
gdb_next {}
gdb_step {}
gdb_print {"var":"counter"}
gdb_full_backtrace {}
gdb_continue {}
gdb_quit {}
gdb_reset_back_to_not_attached {}
Examples of Debugging on gdbserver on exsisting PID:
gdb_gdbserver {"ip":"127.0.0.1","port":11444,"pid":149104}
gdb_target_remote {"ip":"127.0.0.1","port":11444}
gdb_debugger_state {}
gdb_add_variable_list {"var":"robot->sim->robot_row"}
gdb_add_breakpoint {"filename":"/home/brosnan/openmcpgdb/openmcpgdb/examples/mazerobot/src/main.c","linenumber":20}
gdb_continue {}
gdb_next {}
gdb_step {}
gdb_print {"var":"counter"}
gdb_full_backtrace {}
gdb_quit {}
gdb_reset_back_to_not_attached {}
Type quit to exit the interactive client.
This server is compatible with MCP clients that support either:
Use MCP server command settings pointing to:
cargo run --bin openmcpgdb -- /home/brosnan/openmcpgdb/openmcpgdb/config.json
And set in config:
"mcp_server_url": "stdio://local"
You can use either mode:
stdio mode:cargo run --bin openmcpgdb -- /home/brosnan/openmcpgdb/openmcpgdb/config.json
"mcp_server_url": "stdio://local"
"mcp_server_url": "https://localhost:9443"
http://localhost:9443
For local development, prefer stdio:
cargo run --bin openmcpgdb -- /home/brosnan/openmcpgdb/openmcpgdb/config.json
with:
"mcp_server_url": "stdio://local"
If you use HTTP transport, point the client to:
http://localhost:9443
https://localhost:9443 is accepted in this project config as a default URL shape, but the current server bind is plain HTTP.
For true TLS HTTPS, run behind a TLS reverse proxy and expose an HTTPS endpoint there.
All tool responses include debugger_state and optional fields like variable_list, backtrace, current_code*, and error.
debugger_state valuesnot attachedfailed to attachgdbserver attachedattachedstopped at breakpointstopped at steppingrunningsigsegvsigabrtsigbussigfpesigillsigtrapsigtermsigkillexitederrorgdb_execute(executable_path)gdb_run()gdb_gdbserver(ip, port, pid)gdb_target_remote(ip, port)gdb_set_thread(id)gdb_set_frame(id)gdb_add_breakpoint(filename, linenumber)gdb_clear_breakpoint(filename, linenumber)gdb_enable_breakpoint(filename, linenumber)gdb_disable_breakpoint(filename, linenumber)gdb_list_breakpoint()gdb_next()gdb_step()gdb_continue()gdb_interrupt()gdb_add_variable_list(var)gdb_del_variable_list(var)gdb_variable_list()gdb_debugger_state()gdb_current_code()gdb_full_backtrace()gdb_info_threads()gdb_info_regs()gdb_print(var)gdb_set_var(var, value)gdb_quit()gdb_kill()gdb_reset_back_to_not_attached()gdb_display_lines_before_current(size)gdb_display_lines_after_current(size)gdb_display_backtrace(size)gdb_display_variable_list(size)gdb_custom(cmd)Run all tests:
cargo test
Included test coverage:
/home/brosnan/openmcpgdb/openmcpgdb/examples/mazerobot//home/brosnan/openmcpgdb/openmcpgdb/examples/mazerobot/maze_robottests/mazerobot_mcp_client.rsInteractive MCP server to control gdb. Fully featured and written in rust
Tools
No tool list yet. Remote servers get one after the first health check.
FAQ
Copy the stdio config for Cursor, Claude Desktop, Claude Code, or VS Code on this page. It uses the publisher's install, not a PlugMCP proxy.
No required environment variable is listed on this record.
Openmcpgdb runs locally over stdio.
Last checked 2026-10-28. Interactive MCP server to control gdb. Fully featured and written in rust
