
Yahboom Raspbot v2 (Boomy) — MCP Server, Webapp & Documentation
📖 Installation Guide — quick start, manual setup, and troubleshooting
Download for Windows:
yahboom-mcp-2.5.0-setup.exe— installer with webapp + embedded backend, one shortcut. The installer is unsigned: SmartScreen will warn — click More info > Run anyway. Claude Desktop users can instead install the MCP bundle (one-liner below).
Quick Start
Claude Desktop only (MCPB bundle):
irm https://github.com/sandraschi/yahboom-mcp/releases/latest/download/install.ps1 | iex
Every other client (Cursor, Windsurf, OpenCode, Claude Code) — stdio via uvx:
{
  "mcpServers": {
    "yahboom-mcp": {
      "command": "uvx",
      "args": ["--from", "git+https://github.com/sandraschi/yahboom-mcp", "yahboom-mcp", "--mode", "stdio"],
      "env": { "YAHBOOM_IP": "192.168.1.11" }
    }
  }
}
Developers from source:
git clone https://github.com/sandraschi/yahboom-mcp
cd yahboom-mcp
just
This opens an interactive dashboard showing all available commands. Run just bootstrap to install dependencies, then just serve or just dev to start.
Manual Setup
If you don't have just installed:
Overview
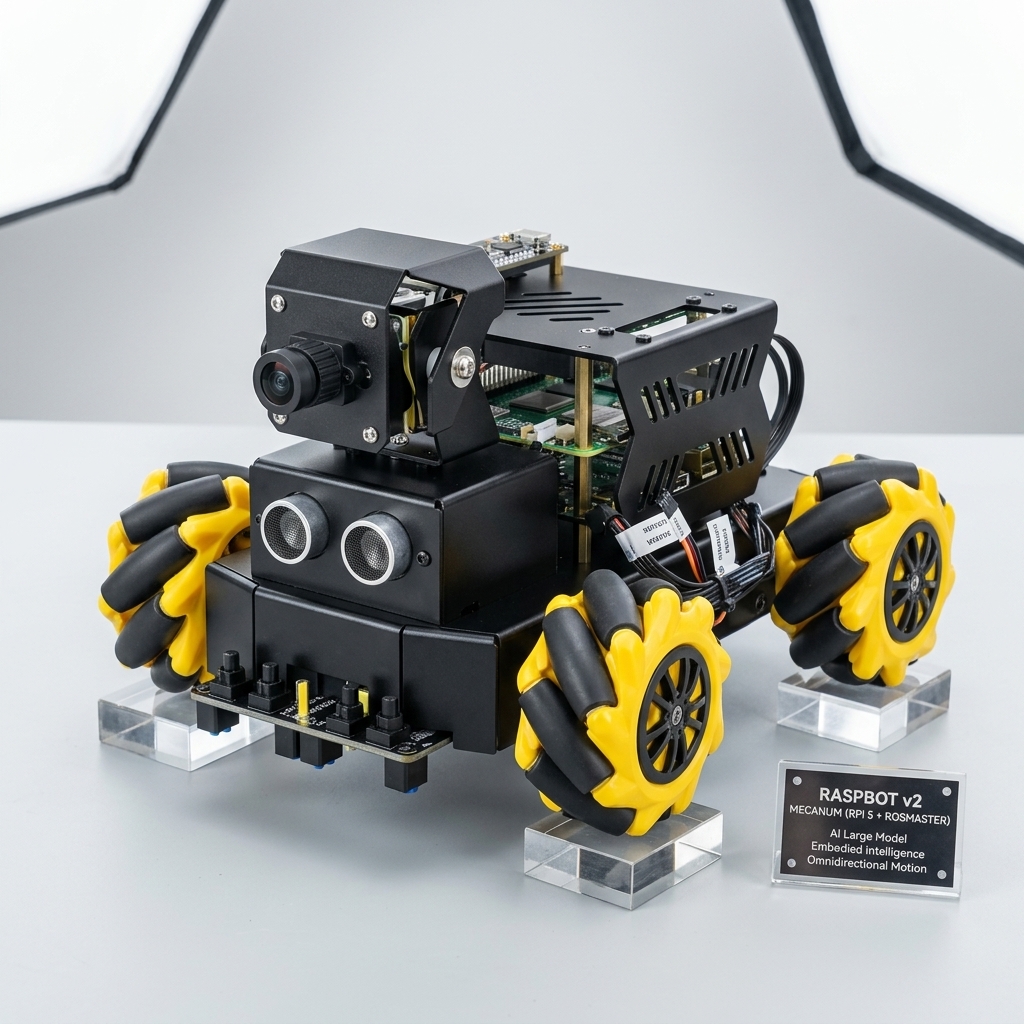
Boomy is a Yahboom Raspbot v2 (Mecanum Version) robot car. Weighing in at approximately 1.0 kg and costing roughly $300 (fully loaded with a Raspberry Pi 5 16GB), it provides a unified platform for testing sensor integration, ROS 2 orchestration, and agentic (AI-driven) robotics. It's also great fun for kids of all ages.
The Manufacturer: Yahboom
Yahboom is a prominent player in the Chinese robotics and STEM education industry. They offer a diverse range of hardware platforms:
- Market Range: From entry-level $50 DIY kits to advanced $2,000+ STEM robots with precision mechanical arms.
- Industry Position: They specialize in accessible hardware for education and prototyping, positioned below enterprise-grade platforms such as Unitree or Noetix.
- Developer Ecosystem: Yahboom maintains a strong commitment to a FOSS (Free and Open Source Software) stack and provides active GitHub support for developers.
🏗️ Hardware Architecture
Boomy utilizes a "Double-Stack" controller model to bridge real-time physical reliability with high-level cognitive tasks:
- Rosmaster (ESP32 / Micro-ROS): Small-form-factor hardware controller for low-latency motor control, ultrasonic pinging, and line-sensor processing.
- Raspberry Pi 5 (Optional / Gateway): The main brain for standalone operation.
🚀 The "Zero-Host" Swarm Config
For scaled deployments, Boomy can operate in a Pi-less Swarm mode:
- Setup: Remove the Raspberry Pi; replace with a WiFi-to-Ethernet/UART bridge ($15).
- Control: Centralized orchestration via a remote Mothership (PC with RTX 4090).
- Scaling: Deploy 3+ units for the price of a single Pi-hosted robot.
🕹️ Interface Separation
This project clearly distinguishes between human-operable controls and machine-optimized interfaces:
- Human Interface: A browser-based Web Dashboard (React/Vite) designed for manual telemetry observation, peripheral control (lights, OLED), and human-robot interaction.
- Machine Interface: A standards-compliant MCP Server (Model Context Protocol) designed for AI agents and MCP clients to programmatic control Boomy as a tool within a larger fleet.
Fleet Crossconnects (Companions)
yahboom-mcp works completely standalone. You can optionally connect it with companion servers in the sandraschi fleet to unlock extended features:
Self-Contained Companions: Fleet companions operate independently. Installing companions does not trigger transitive dependency chains.
📂 Documentation Pillars
Webapp status surfaces
- Dashboard (
/dashboard) — First page: basic robot link (gateway, target IP, ROS · SSH · video) and operator hints when the Raspbot is off or Goliath has no AP/Ethernet path. - Diagnostic Hub (
/diagnostics) — Detail: ROS topic explorer, node list, resync / hard reset, SSH shell, stack health table (samestackpayload as the dashboard when available). - Server logs (
/logs) — Live yahboom-mcp log stream (SSE) on Goliath.
Historical status logs and legacy research are preserved in the docs/archive/ directory.
Stack
🛡️ Industrial Quality Stack
This project adheres to SOTA 2026 industrial standards for high-fidelity agentic orchestration:
- Python (Core): Ruff for linting and formatting. Zero-tolerance for
printstatements in core handlers (T201). - Webapp (UI): Biome for sub-millisecond linting.
- MCP: FastMCP 3.4 with Unified Gateway, portmanteau tools, skills, and agentic sampling.
- LLM Providers: Auto-discovery of Ollama (
:11434) and LM Studio (:1234). GPU metrics via nvidia-smi. - Automation: Justfile recipes for all fleet operations (
just lint,just fix,just dev).